M1Personal project · robotics
Hexapod walking robot
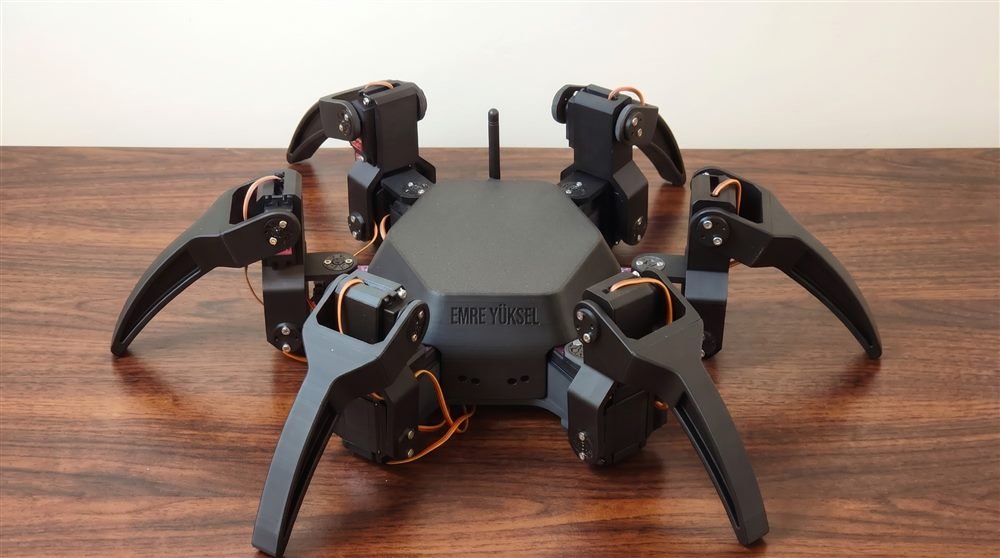
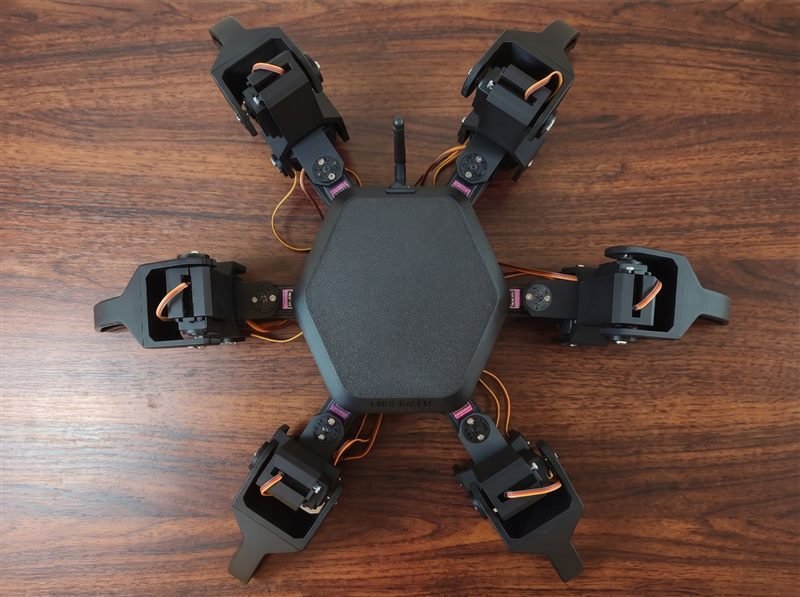
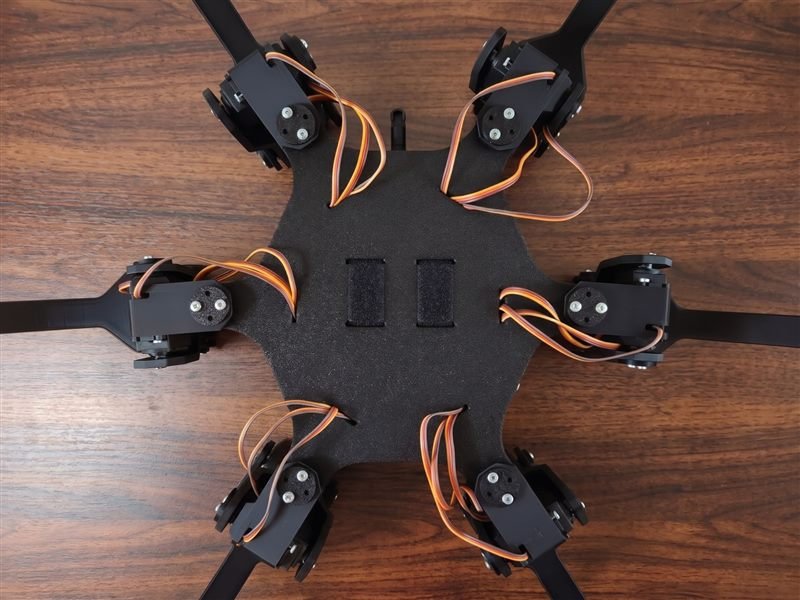
A six-legged robot I designed myself: body and legs modelled in FreeCAD and 3D-printed, electronics laid out in KiCad, and C/C++ firmware driving three servos per leg.
Embedded Systems Engineer · MSc candidate
I write bare-metal firmware for STM32 and PIC microcontrollers and design the boards it runs on.
Now at the University of Siegen, I’m researching how to optimise LLMs to generate safe, deterministic, and power-efficient C/C++ for resource-constrained hardware.
I'm an embedded systems engineer with a BSc in Electrical-Electronics Engineering, now doing an MSc in Embedded Intelligence Nanosystems Engineering at the University of Siegen.
In defence electronics I wrote bare-metal firmware for STM32 and PIC, built peripheral drivers and real-time control loops, and designed avionics hardware: schematics, multi-layer PCBs and power circuits, validated on the bench with scopes and logic analysers.
My current focus is AI for edge devices: deep learning on constrained hardware, and optimising large language models to generate safe, deterministic, power-efficient C/C++ for embedded systems design.
| Discipline | Embedded firmware & hardware |
|---|---|
| Platforms | STM32 (ARM Cortex) · PIC |
| Industry | Defence & avionics (2023–2025) |
| Current focus | Edge AI · LLMs |
| Location | Siegen, Germany |
| Languages |
|
A six-legged robot I designed myself: body and legs modelled in FreeCAD and 3D-printed, electronics laid out in KiCad, and C/C++ firmware driving three servos per leg.
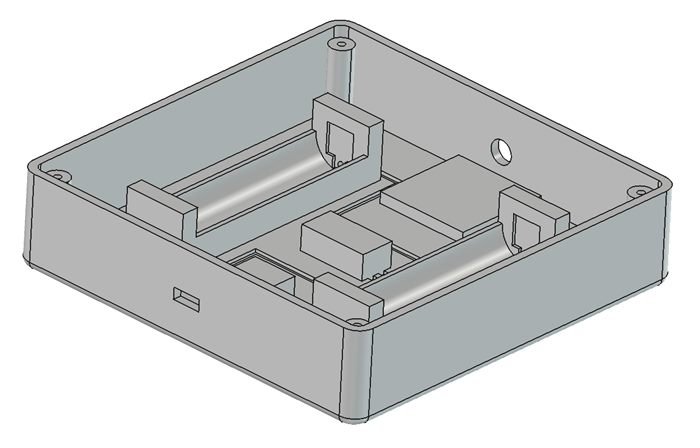
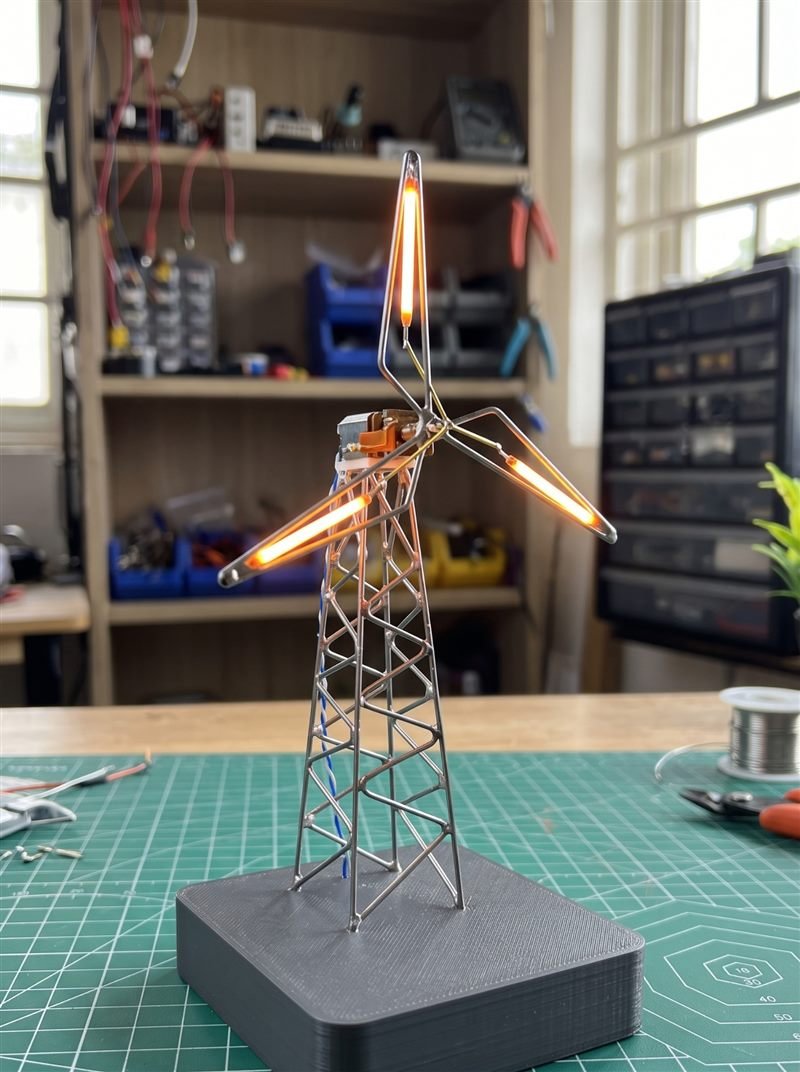
I designed the PCBs that drive it: PWM control for the rotor motor, a USB-C charger and a 1S BMS protecting two parallel 18650 cells, all housed in a 3D-printed base.
All of my information on a single page, in PDF format.
resume.pdf · 1 page